TL;DR
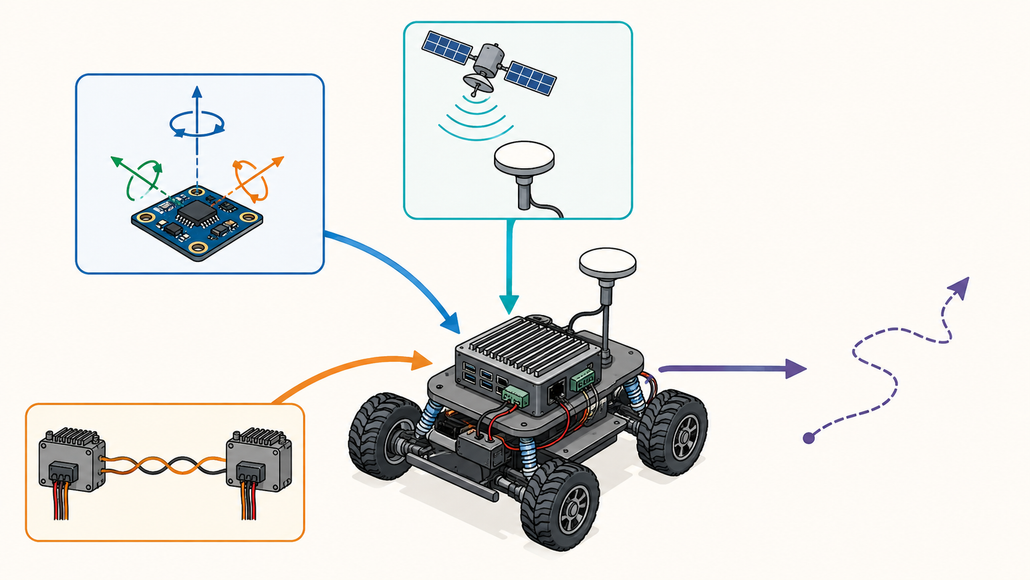
The article dives into mobile robot development, focusing on how robots determine their movement using various sensors like LiDAR, Inertial Measurement Units (IMUs), and wheel encoders through a process called sensor fusion. It highlights the challenges that arise when a robot is in motion, such as the discrepancies in point cloud data and the complexities of time alignment between different sensors.