TL;DR
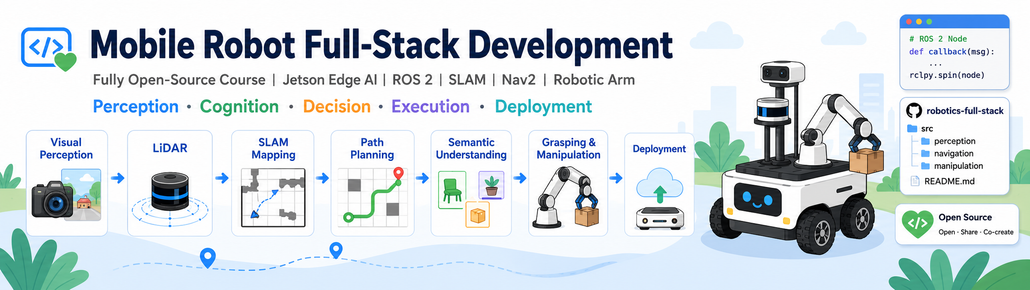
The article delves into the practical aspects of equipping a mobile robot with vision capabilities using a GMSL2 (Gigabit Multimedia Serial Link) multi-camera setup. It builds on the foundation laid in the previous installment of the "Mobile Robot Full-stack Development In Practice" series, where a Jetson-powered platform was established to facilitate robotics development. Now, the focus shifts to ensuring that the robot can accurately perceive its environment through effective sensor fusion and calibration techniques.